Work / Self-driving simulator
StreetLab
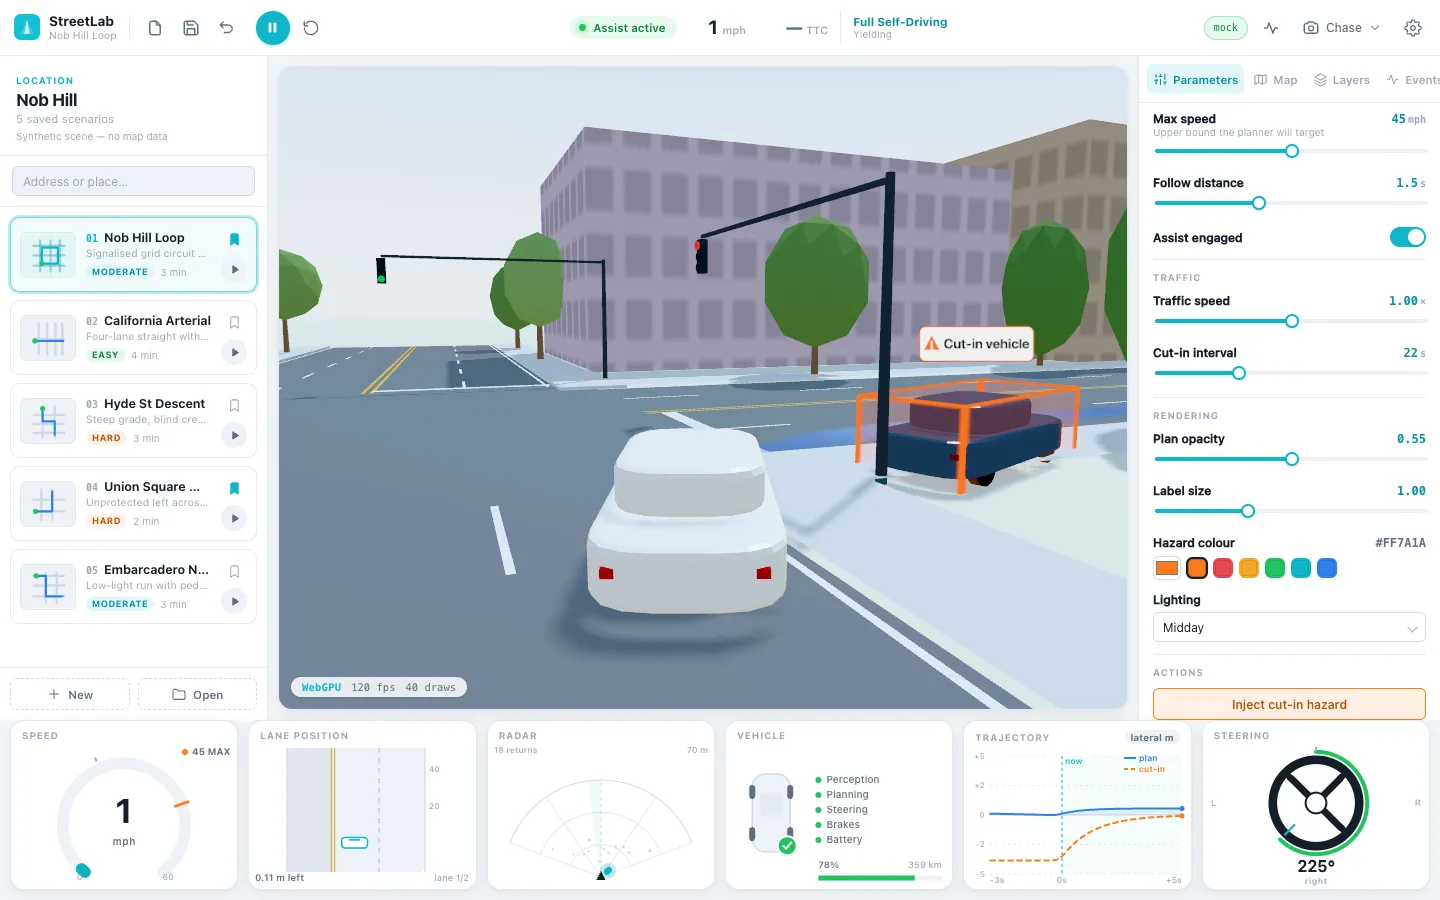
Point it at any real address and a simulated car drives the actual streets, obeying signals and reacting to traffic.
- Role
- Solo build
- Year
- Aug 2026–present
- Status
- Cycles 1–5 built; still active
- Stack
- Rust, Tauri 2, TypeScript, React, Three.js over WebGPU, Python, FastAPI WebSockets, ONNX Runtime, OpenStreetMap
- Links
- Repo
Problem
I wanted to go deep on real-time graphics, deterministic simulation and applied ML as a system rather than a notebook, and to treat every performance claim as something to measure. It is a portfolio and learning project, not a production AV system.
What I built
A native desktop app that geocodes any real address, pulls actual street and building geometry from OpenStreetMap, and drives a simulated car through it, obeying traffic lights and stop signs and reacting to other traffic.
Every message between the simulation and the UI is validated against one schema on both sides.
Result
1,100+ automated tests, all green (910 backend, 205 frontend, 12 end-to-end). 30–60 FPS in the WebGPU viewport. Built in five cycles, each added without touching the earlier ones.